Mobility / Grashof's Condition and Barker's Classification
Mobility of Mechanism
Degrees of freedom for planar linkages joined with common joints can be calculated through Gruebler’s equation.
Gruebler’s equation is given by the formula:
M = 3(L-1) - 2J1 - J2
where:
- M is degree of freedom or Mobility
- L is number of links
- J1 is number of full joints
- J2 is number of half joints

Grashof Condition
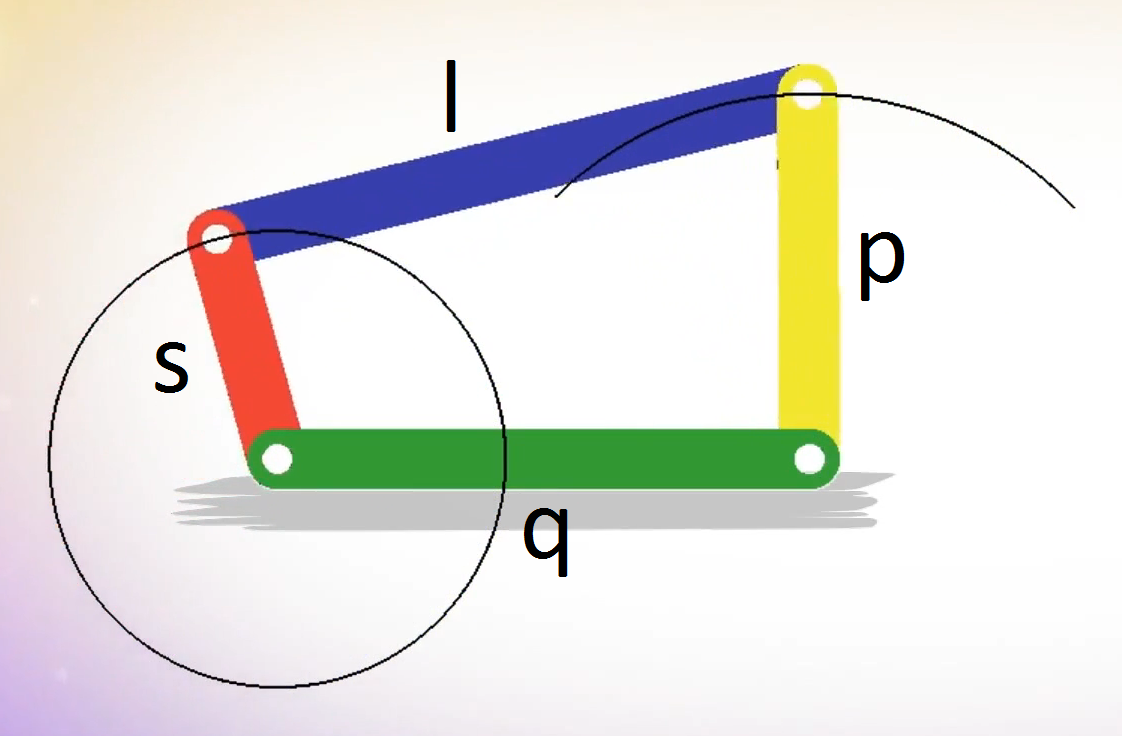
Grashof’s Law states that for a four-bar linkage system, if the sum of length of shortest and longest of a planar quadrilateral linkage is less than or equal to the sum of the remaining two links , then the shortest link can rotate freely with respect to neighbouring link.
Let denote the smallest link of four bar linkage with S and the longest link by L and the other two links by P and Q.

The necessary condition to satisfy Grashof’s Law is :
S + L ≤ P + Q
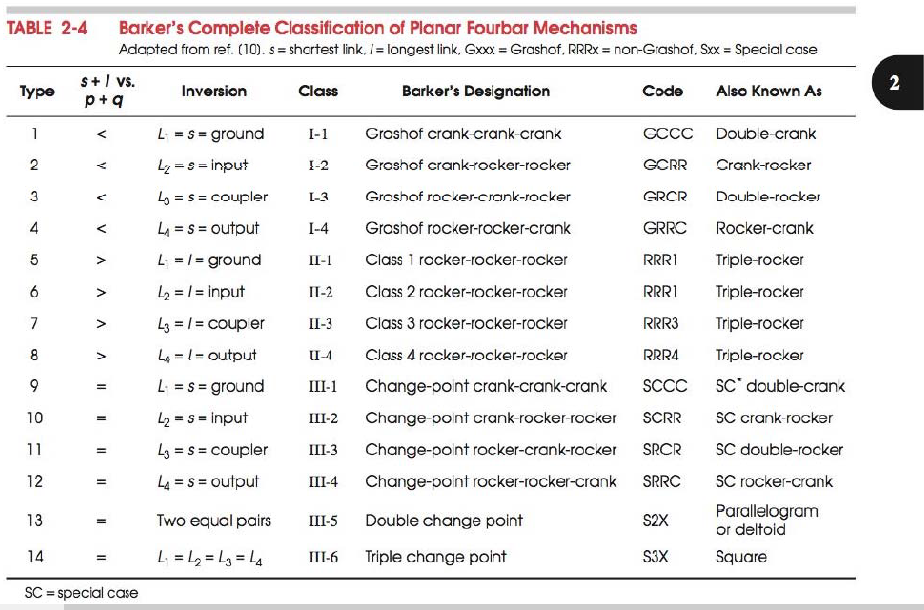
Barker's Classification
Try Yourself
About the author
I'm a Multan, Pakistan based Mechanical Engineer. I push pixels, shuffle data, and slap my keyboard until everything works.
Comments
Join the discussionNo comments yet. Be the first to comment.


