
Arduino vs Raspberry PI
Which one to use when/why?
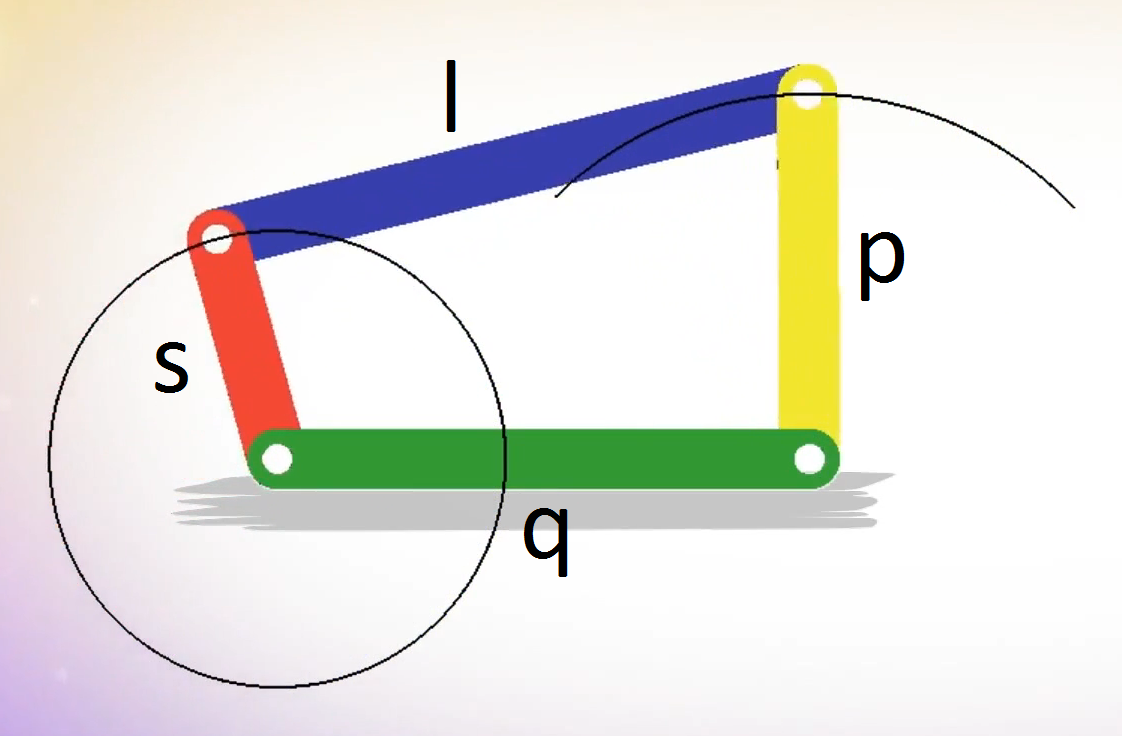
Mobility of Mechanism Degrees of freedom for planar linkages joined with common joints can be calculated through Gruebler’s equation. Gruebler’s equation is given by the formula: M = 3(L-1) - 2J1 - J2 where: M is degree of freedom or Mobility L is...
Gruebler's Equation


